16 years one-stop China custom CNC machining parts factory
The VMT blog is dedicated to sharing our hard-earned knowledge in prototype manufacturing. We hope these articles will help you optimize your product designs and gain deeper insight into the world of rapid prototyping. Enjoy the read!
Get an Instant Quote All uploads files are safe and confidential
 VMT
 2026 11 18
Learn the main types of robotic end effector and EOAT components, including gripper fingers, gripper bodies, adapter plates, tooling frames, tool changer interfaces, vacuum manifolds and sensor mounts. Compare materials, 3-axis vs 4-axis vs 5-axis CNC machining, DFM, datum and tolerance control, CNC vs 3D printing, and hybrid manufacturing for precision robotic end-of-arm tooling.
 66
 Read more
 VMT 2026 11 17
Different robotic hand grasping modes require different mechanical and manufacturing priorities. Pinch grasp depends more heavily on fingertip positioning, miniature joint fits, and backlash control; power grasp requires greater phalanx rigidity and stable thin-wall structures; and adaptive grasp relies on controlled linkage clearances and low-friction tendon routing. For CNC-machined dexterous hand components, these kinematic requirements should be translated into material, tolerance, surface-finish, and machining decisions during the DFM stage to reduce joint binding, tendon wear, structural deformation, and prototype rework.
66
Read more
 VMT 2026 11 16
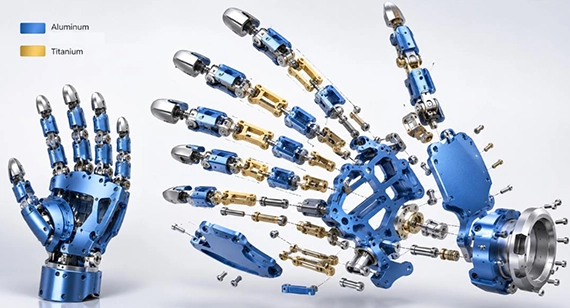
Aluminum alloys are generally better suited to lightweight dexterous hand structures where heat dissipation, machining efficiency, and cost are important considerations. Typical applications include finger skeletons, motor housings, and selected joint enclosures. Titanium alloys, on the other hand, are more suitable for miniature joints and connecting components that require high strength, fatigue resistance, wear resistance, and load-bearing capacity within limited space. But the final material selection should be based on the component's loading conditions, motion frequency, thermal management requirements, and machining considerations.
66
Read more
 VMT 2026 11 16
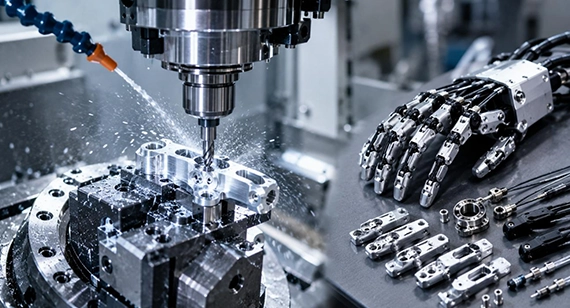
Successful CNC manufacturing of robotic dexterous finger parts depends on controlling miniature geometry, thin-wall deformation, joint alignment, tendon-routing surface quality, and coating-related dimensional changes as one integrated process. For high-precision finger links, joint housings, hinge interfaces, and tendon components, simultaneous 5-axis machining, micro-tool control, low-force custom fixturing, GD&T-based inspection, and reliable micro-burr removal are often more important than machine accuracy alone. When these factors are planned during the DFM stage, manufacturers can reduce joint binding, cable wear, thin-wall distortion, assembly variation, and costly prototype rework.
66
Read more
 VMT 2026 11 16
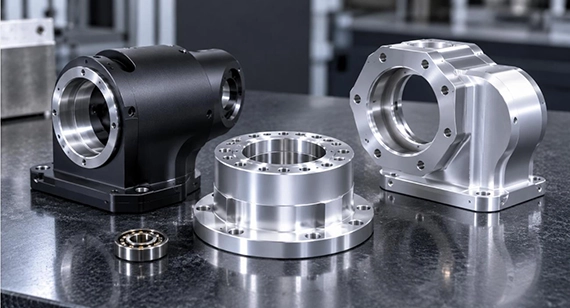
Learn how custom CNC robot actuator housings are designed and manufactured, including housing types, CNC vs 3D printing and die casting, bearing bore and coaxiality control, thin-wall machining, 6061 vs 7075 vs titanium material selection, anodizing and surface finishes, and prototype-to-production planning. See how a validated die-casting + CNC process delivered 60,000 precision motor housings in 35 days.
66
Read more
 VMT 2026 11 11
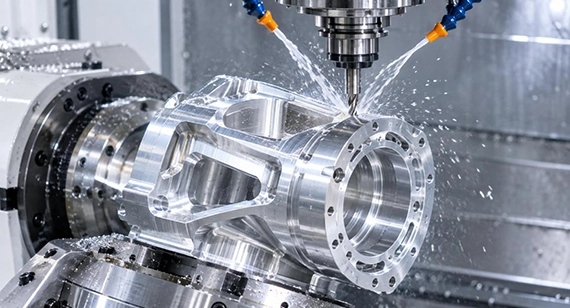
For custom robotic joint housings subjected to high-torque dynamics and continuous transmission loads from harmonic drives or RV reducers, CNC machining remains the undisputed manufacturing standard. It delivers superior isotropic rigidity, extreme coaxiality tolerances (±0.005 mm to ±0.01 mm), and exceptional heat dissipation that additive methods cannot match. Beyond structural containment, a precision-machined joint casing serves four critical functional roles: maintaining IP65/IP67 hermetic sealing, aligning dual bearing journals, dissipating thermal build-up from frameless torque motors, and providing essential electromagnetic interference (EMI) shielding for sensitive encoders. For high-precision robotic joints, these functions must be considered together with datum strategy, wall thickness, material selection, surface finishing, and assembly tolerances from the DFM stage.
66
Read more
 VMT 2026 11 09
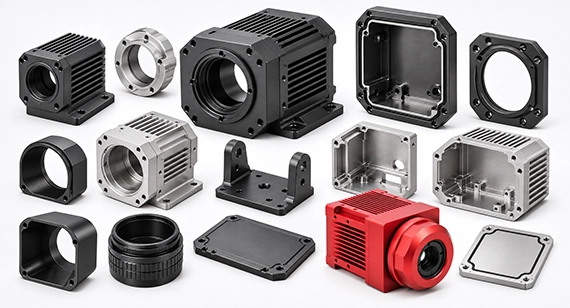
For smart thermal imaging systems, a CNC-machined camera housing is not merely a protective enclosure; it is part of the optomechanical, thermal, sealing, and EMI performance chain. Reliable housing design requires the optical datum, thin-wall stability, thermal-contact surfaces, O-ring sealing geometry, internal component interfaces, and surface-treatment allowances to be planned together during the DFM stage. When these relationships are controlled as one integrated system, manufacturers can reduce optical misalignment, thermal drift, assembly interference, sealing failures, and costly rework before volume production.
66
Read more
 VMT 2026 11 09
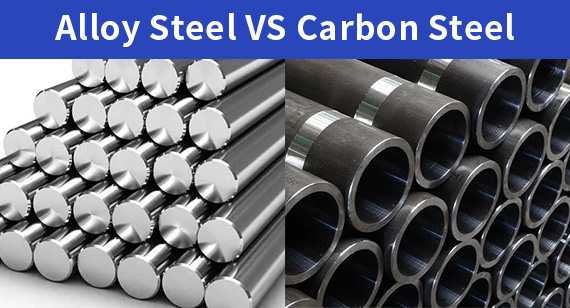
In the field of CNC machining parts manufacturing, selecting the right material is one of the key factors to ensure product quality and performance. Alloy steel and carbon steel are two common metal materials, each with unique physical and chemical properties and a wide range of applications. This article aims to help readers understand the differences and distinctions between alloy steel and carbon steel through detailed comparative analysis, as well as how to choose the right material for different application scenarios.
66
Read more


 +86 15099911516